Goals
This week, we wanted to keep testing on Comp 2026 code. Our top priority right now is getting our competition code merged into main. Unfortunately, that could not happen this week since Crush was not available for testing. Our goals for this week were as follows:
- Test DVL and state when it goes over objects (e.g., bins)
- Test move to pose for further distances and at larger trials to ensure state is fine
- Test smoothed movement tasks
- Test sonar at further distances
Movement
We started by trying to test our movement. Unfortunately, we found out that the gyroscope was not working. After a lengthy debugging process with calling every electrical lead, we pivoted to making this a Sonar-focused pool test.
Sonar
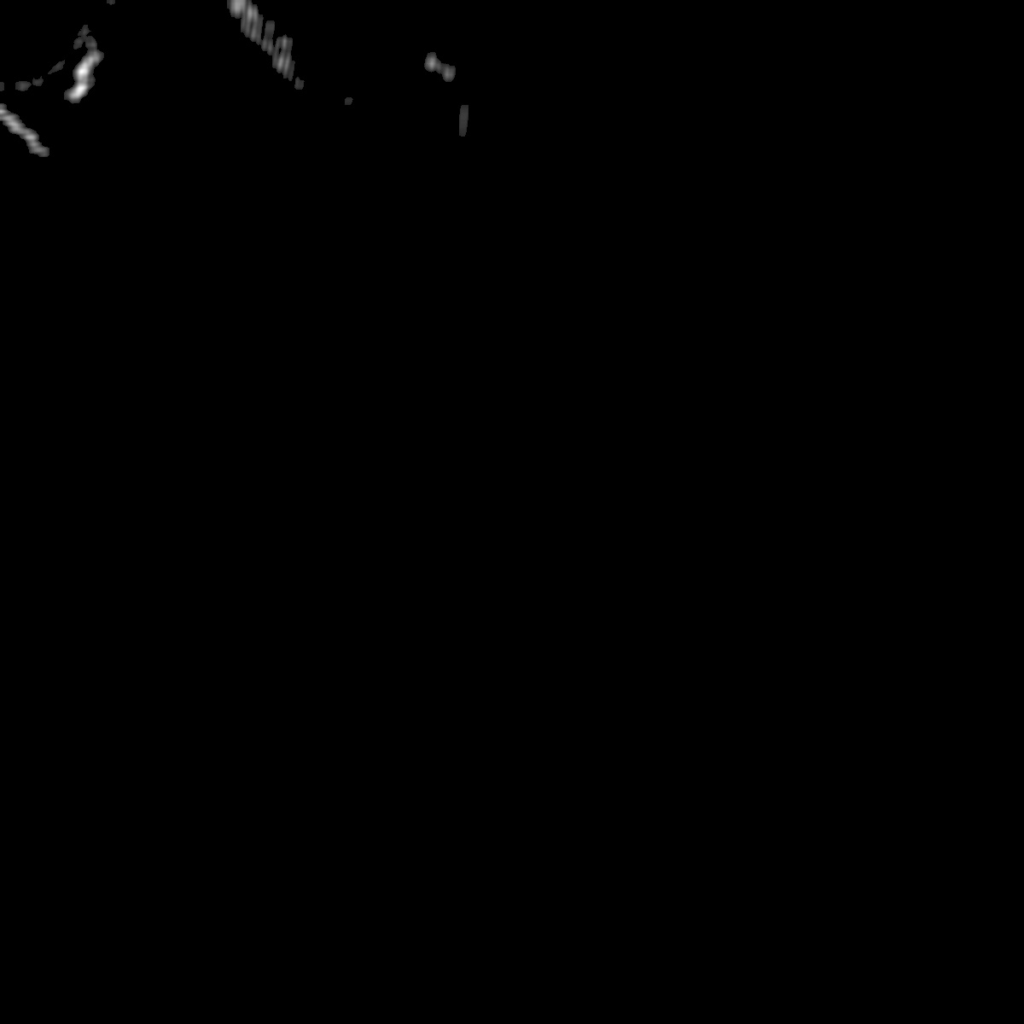
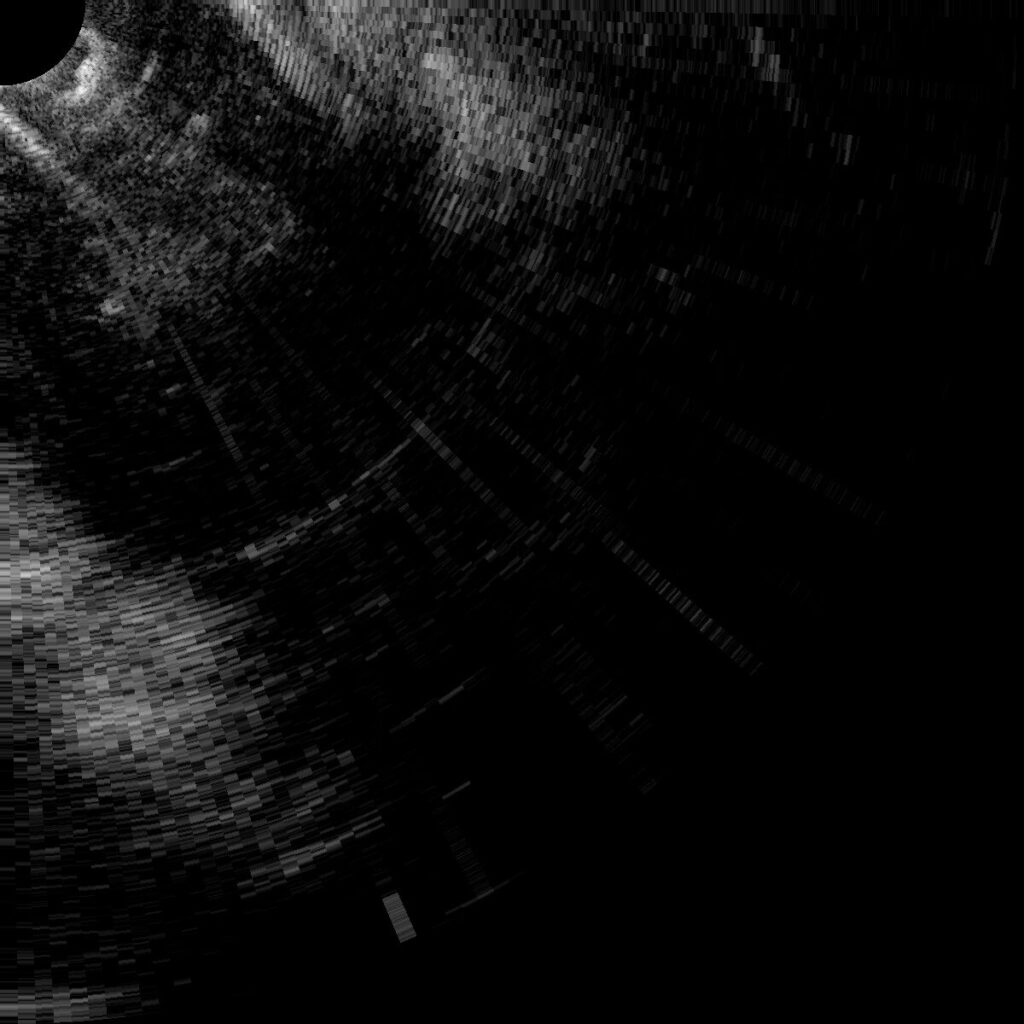
The majority of this pool test was related to testing our current sonar processing and position estimation algorithm with objects other than a wall. We collected data for the torpedo gate and a simulated slalom, and found that our raw data has clear indications of both the slalom and torpedo gate, but the processing algorithm is likely overfit to work with walls. In the future, we can continue to improve upon this algorithm to make it more generalized for different objects (i.e., wall vs slalom vs torpedo gate).
Conclusion
Despite the gyroscope not working (props to Sid for debugging what happened after the pool test), this one was pretty productive. We now have data for sonar images which will be very important. Also, we will test Crush ASAP in order to get robosub-2026 merged into main. The current projects are the same as always, though, with good working being done on acoustics, simulation, and CV. Adios!